Syed Mahin Shah — Robotics Engineer, Founder, Filmmaker Syed Mahin Shah — Robotics Engineer, Founder, Filmmaker
Skip to content
SMS SYED MAHIN SHAH
OPENING TC 00:00:00:00
REEL 00 — OPENING TITLES WORCESTER, MA ⇄ LAHORE, PK

I build machines that think, systems that remember, and stories that keep you up at night.

  • ROBOTICS ENGINEERING · WPI ’28
  • FOUNDER & SYSTEMS ARCHITECT · ANTHEON
  • DIRECTOR OF OPERATIONS · FES
  • PRODUCER & LEAD · NARCOLEPSIA
PSST — POKE THE ROBOT SCROLL TO ROLL FILM ↓
COLD OPEN

A robotics engineer at WPI.

A founder building an AI that remembers.

An operator at a firm that has placed 15,000 students.

The lead in a horror film Pakistan hadn’t tried before.

Same person. Different reels.

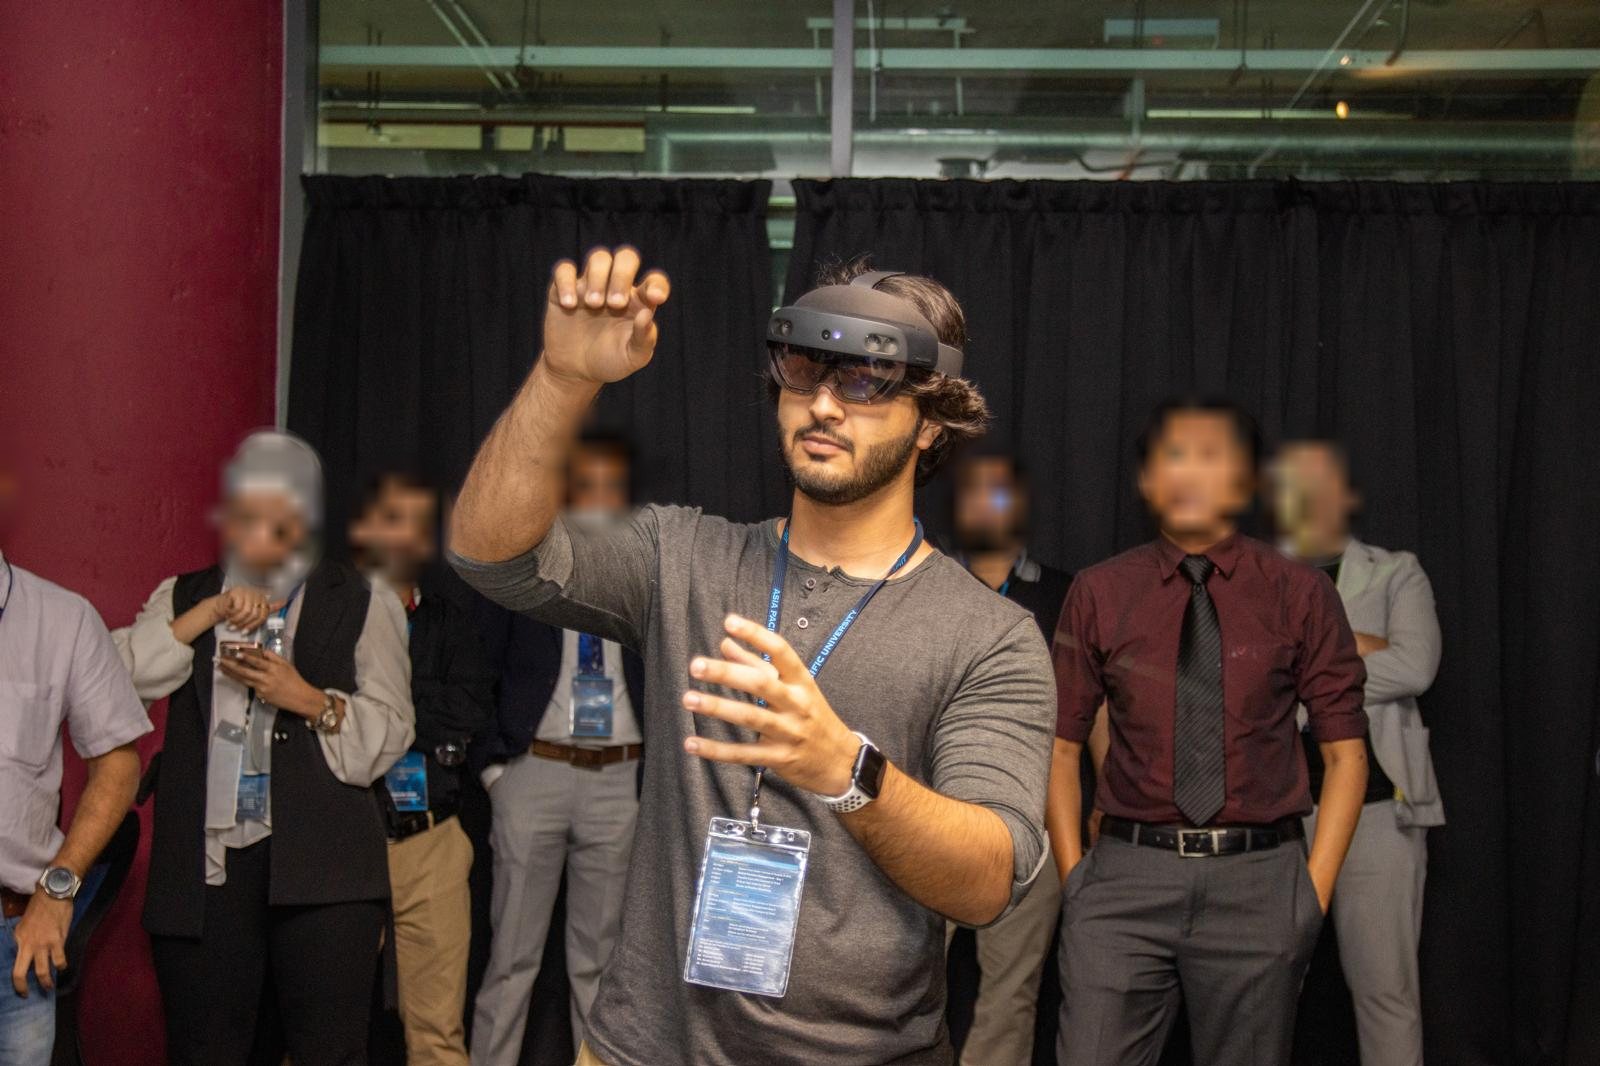
Mahin wearing a HoloLens headset, reaching into a hologram while a crowd watches; bystanders' faces are blurred
FRAME 0112 · MIXED REALITY
Hands in the hologram. APU.FIG. 01
REEL 01 — GADGETS LAB · BUILD 01

Rocky

A palm-sized desk robot with his own local brain.

SCENE 1 · WHAT HE IS

He talks, keeps time, watches the desk — and keeps working with the laptop shut.

SCENE 2 · OPEN HIM UP

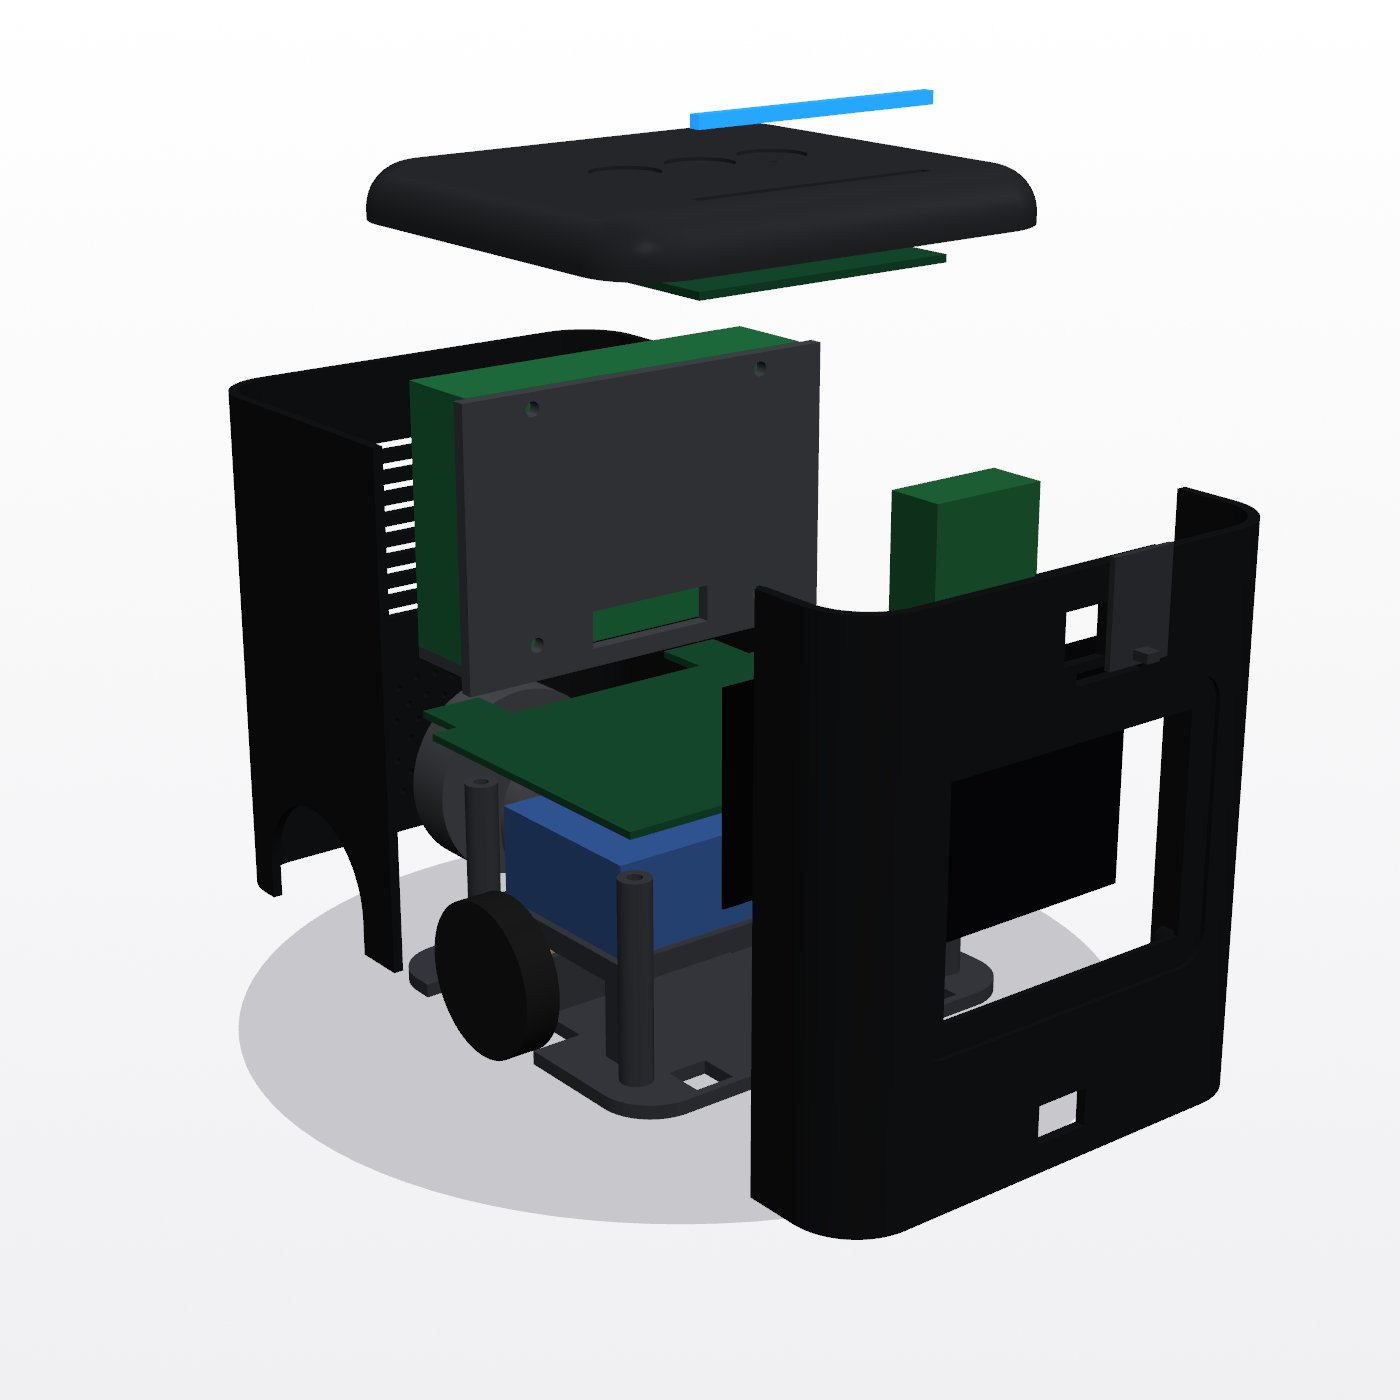
Ten printed parts. Two custom PCBs. Zero clashes across 22 bodies.

These are the real CadQuery STL files. Hover a part.

SCENE 3 · WHY IT FITS

Every dimension is a named parameter. Change one, re-run, and the whole body updates.

BILL OF PARTS● DESIGNED BY ME
  1. 01Top cap + light pipe●
  2. 02Crown PCB — touch, mic, LEDs●
  3. 03Front shell + privacy slider●
  4. 042.8″ face, drawn by the ESP32○
  5. 05Camera Module 3○
  6. 06Raspberry Pi 5 — the brain○
  7. 07Spine PCB — power, motors, body chip●
  8. 08Mid frame●
  9. 092×18650 battery + strap●
  10. 10Sealed speaker box●
  11. 11Rear shell — vents, USB-C●
  12. 12N20 motors, clamps, wheels●
  13. 13Chassis base + caster●
135 × 105 × 95 mm · ~223 g PETG · vendor parts shown at datasheet size

Three layers.
Break one.

Each layer keeps working when the one above it fails. Go on — try to make him unsafe.

ERIS Hub {{ ly.eris.t }} laptop · supervisor · long-term memory · heavy thinking
TAILSCALE · ENCRYPTED · MY DEVICES ONLY
Layer 2 · Brain {{ ly.brain.t }} Raspberry Pi 5 · voice · camera · policy · short-term memory
Layer 1 · Body {{ ly.body.t }} ESP32-S3 core 1 · face · motors · sensors · LEDs
Layer 0 · Reflexes {{ ly.reflex.t }} ESP32-S3 core 0 · edge stop · lift stop · heartbeat-loss stop · stall cutoff · low-battery shutdown

{{ ly.msg }}

FACE · 320 × 240 · LANDSCAPEDRAWN BY THE ESP32
{{ fv.top }}
24:13
SAFE
{{ fv.sub }}
ROCKY
waiting for brain…
{{ fv.caption }}
{{ fv.fl }}{{ fv.fr }}

The screen is wired to the body chip, not the Pi — so he can still show a fault when his brain is dead. Ion blue means attention. Red means faults, and only faults.

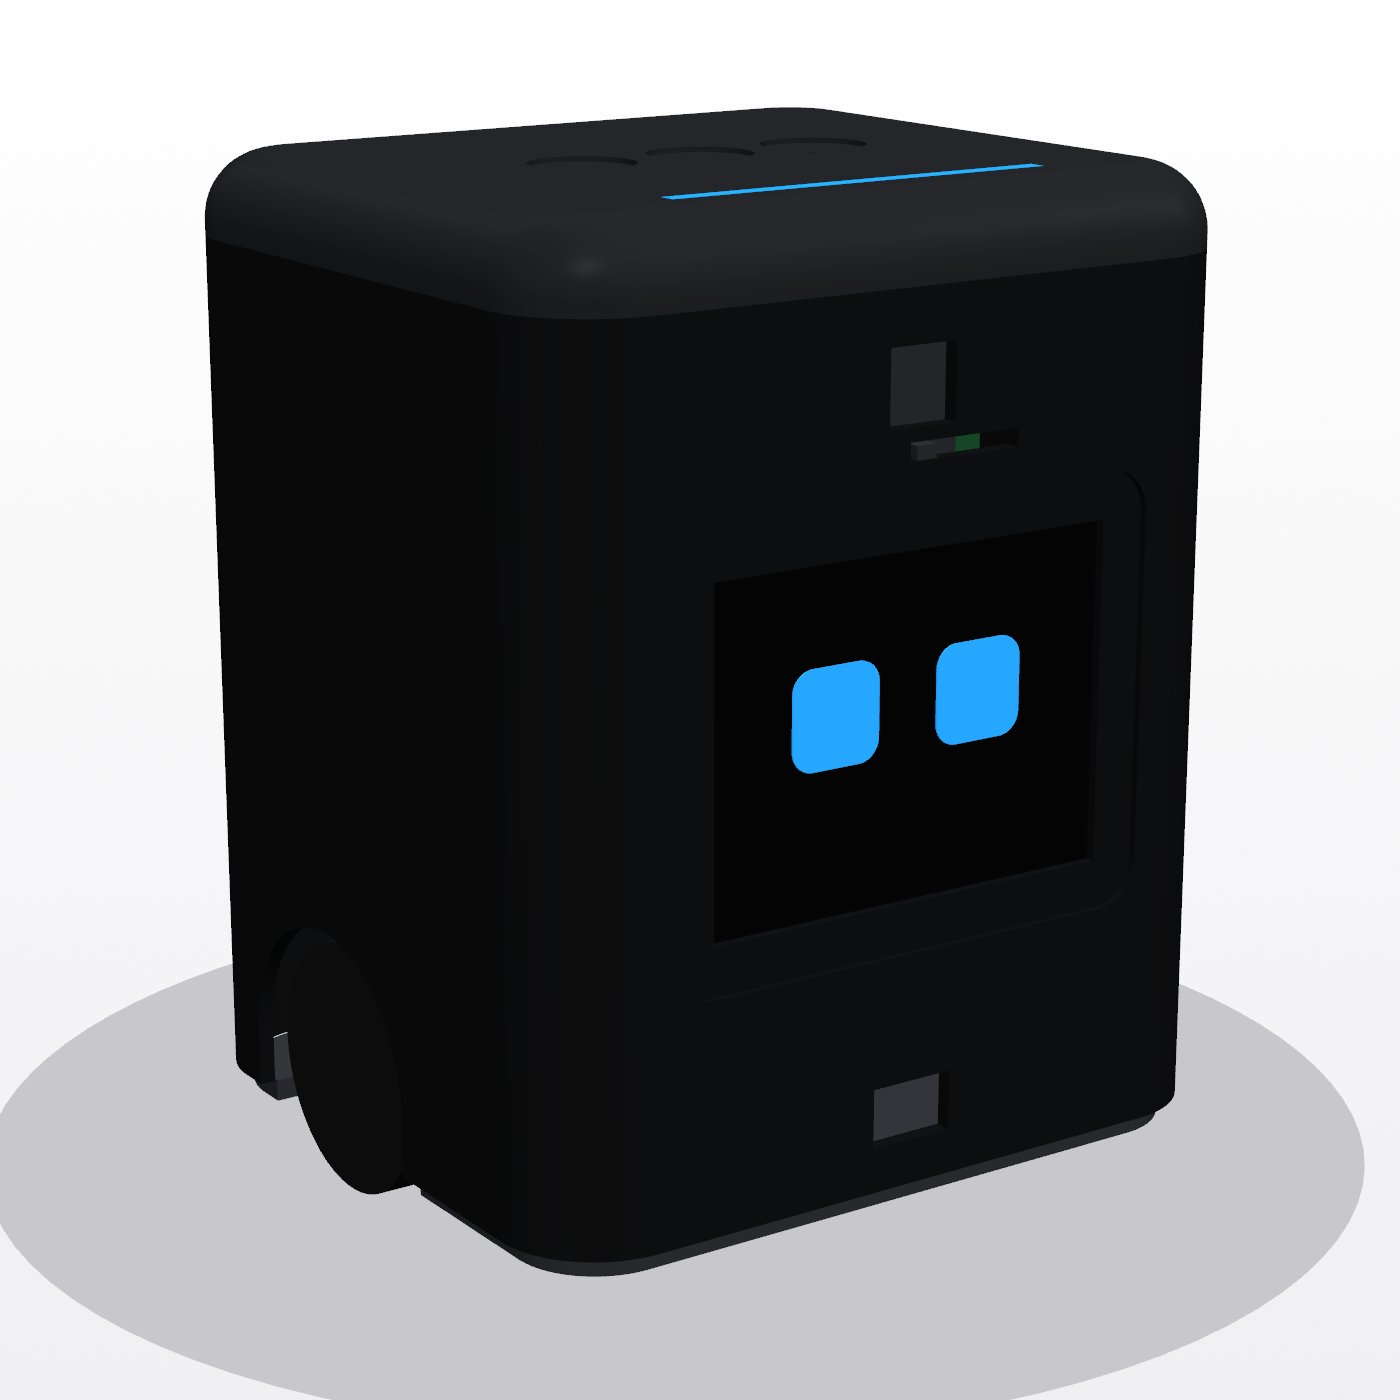
Render of Rocky from the front: a dark rounded box with blue square eyes on a screen
Render · front
Exploded render of Rocky showing shells, PCBs, battery and Pi
Exploded · 22 bodies, 0 clashes
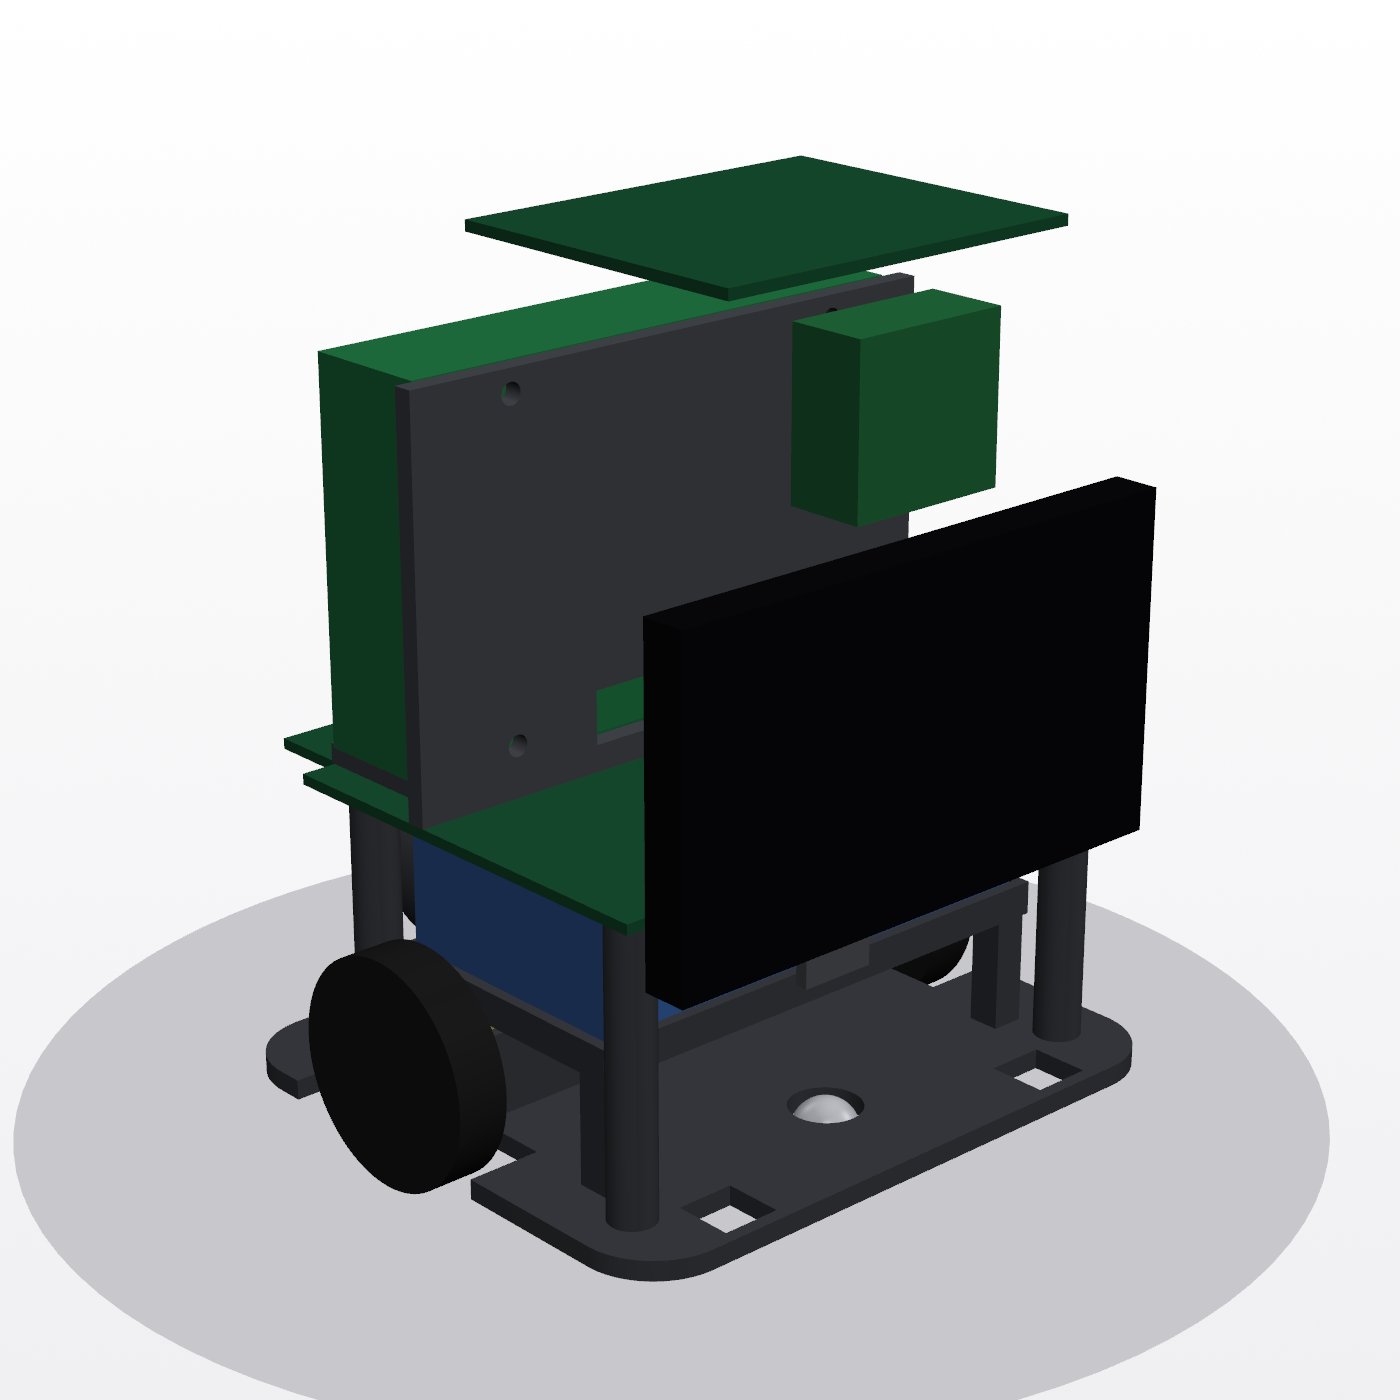
Cutaway render showing the internal layer cake of Rocky
Cutaway · motors → battery → Spine → Pi
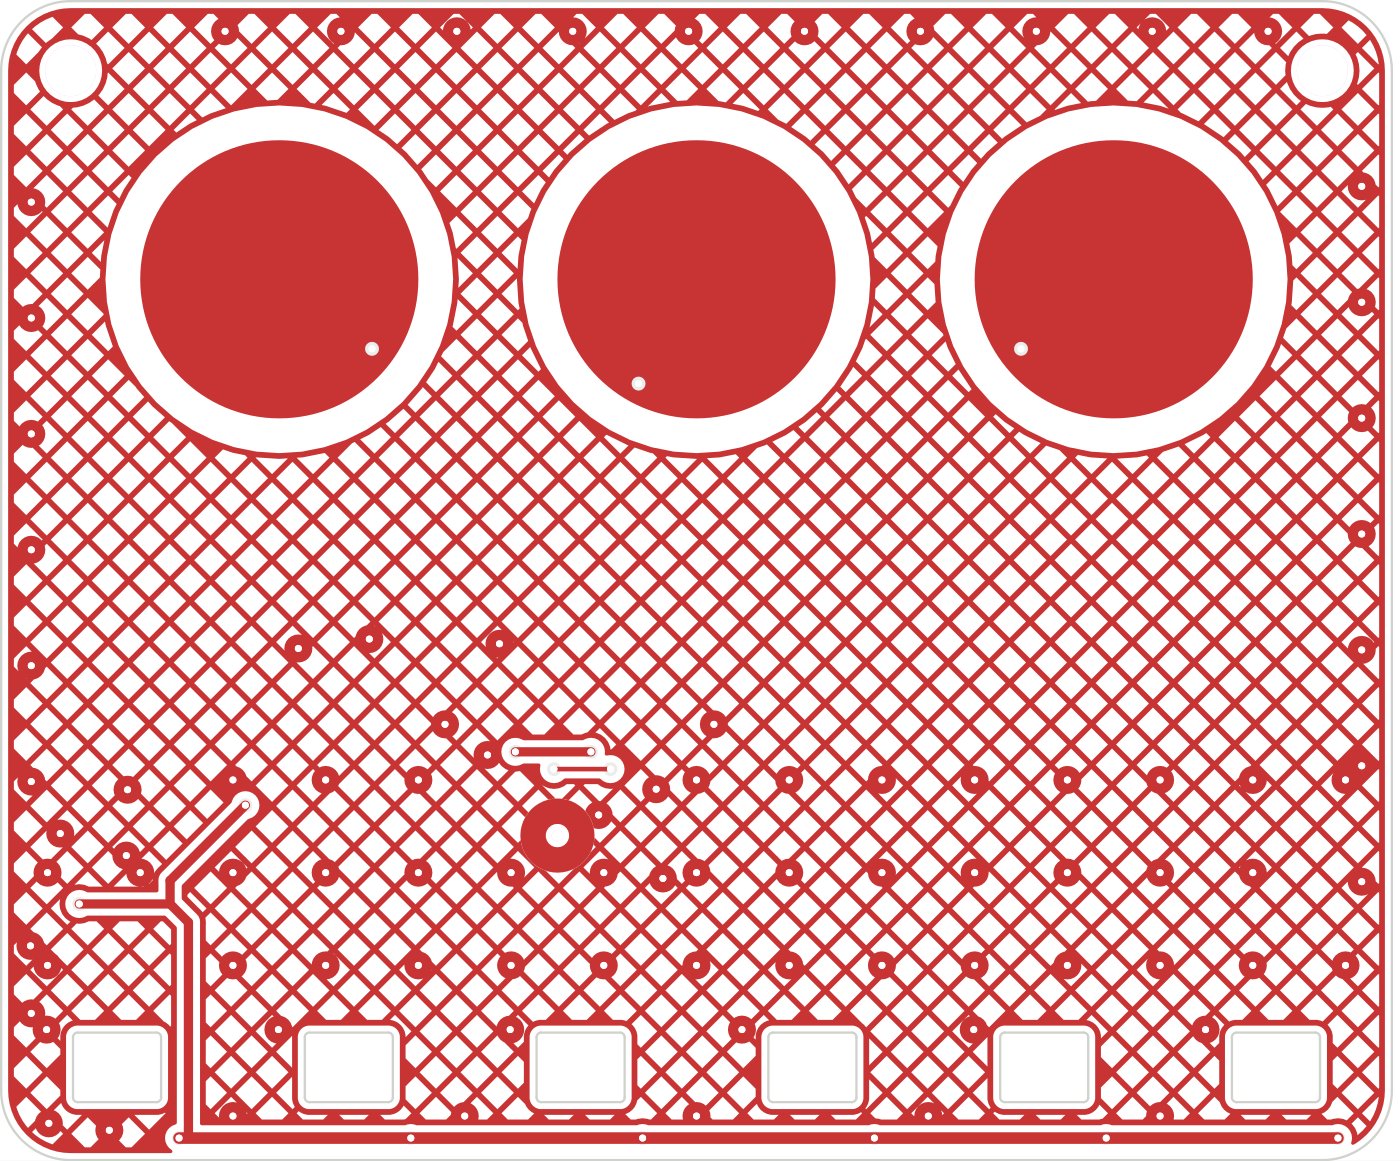
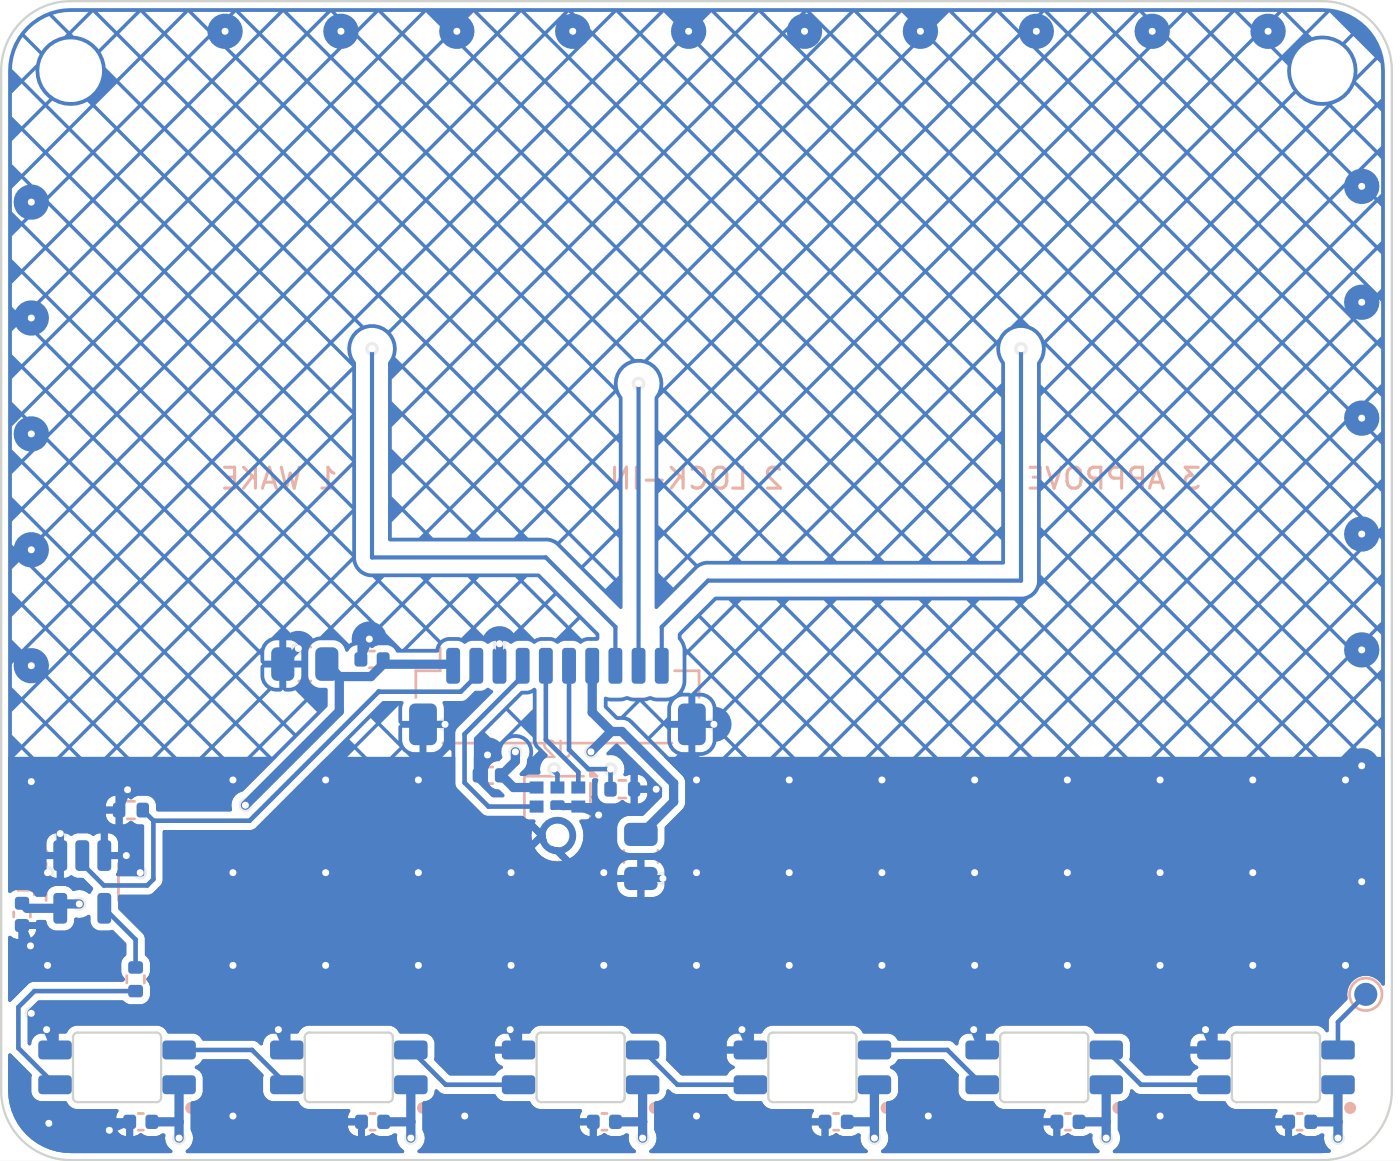
Crown PCB top copper layer: three touch pads and an LED row Crown PCB bottom copper layer
Crown PCB · KiCad 9 · ERC/DRC clean · hover to flip
BUILD LOG
  1. 2026·09·19Picked and re-scoped: Pi 5 brain, ESP32-S3 body, two custom PCBs, ERIS-supervised.
  2. 2026·09·26Pi program and simulator written, firmware links for the ESP32-S3, CAD concept clash-free.
  3. 2026·09·30Crown PCB drawn; ERC and DRC clean in KiCad 9; footprints match the fab.
  4. 2026·10·01A local 1B-parameter brain running in the simulator. Persona drafted.
  5. 2026·10·04Soldering done. Amp, speaker and mic working. Wake word proven. First spoken exchange on the Pi.
  6. NEXTThe Spine PCB, the printed shell, and wheels on the real desk.
BY THE NUMBERS
351
firmware checks + tests, green
≤1.5 s
target to first spoken word, laptop off
3
layers that fail independently
0
raw audio or video ever stored
REEL 02 — ANTHEON · FLAGSHIP SYSTEM

ERIS

A personal AI with a long memory — built to act, not just answer.

Twelve subsystems with clean seams — one hub orchestrating, heavy organs split into their own processes.

Memory is a weighted blend of similarity, recency, salience, identity and project. Identity loads in full, every turn.

Watch a request travel: in through the interface, past governance, out through one gated action — observed the whole way.

The Sovereign Interface
chat · voice · screen · cross-device
Orchestration
task graph · schedule · time · long-running ops
Perception
text · voice · screen · vision
The Kernel
pick a pattern · reason · stream
Action
tools behind one gate · three tiers
Memory
working · episodic · semantic · procedural — hot · warm · cold · archive
Identity
persona + profile, never retrieved
Ingestion
email · calendar · files · vault
Evolution
procedures · generated tools · tuning
Governance · the Vault
encrypted secrets · audit · trust gradient · injection defence
The Observer
health · cost meter · telemetry · status
CONNECTED ECOSYSTEM · HUB + SPOKES
01 · HYBRID BRAIN

Frontier API for the hard reasoning. A local model for private work and as the fallback when the network isn’t there.

02 · ISOLATED EXECUTOR

Tools run in a separate child process. Execution moved out; authorisation never did — the gate and the audit stay in the hub.

03 · UNDO, BY DESIGN

Every action is logged with what was planned and what actually happened. Reversible classes carry their inverse.

04 · A METER ON EVERYTHING

Each action is costed as it runs, so a long job can’t quietly burn money in the background.

05 · READ BY INSTRUMENT

Phase gates are scored by a command, not a feeling. One measured run: a three-hour operation with 110 distinct updates.

06 · THE LADDER

A change is built on a second ERIS, proven by her own tests, and promoted only on the numbers — with the old body kept for rollback.

FIVE PROCESSES · HUB · EXECUTOR · VOICE · DESKTOP SIDECAR · WEB — PHASE 3 IN PROGRESS

REEL 03 — WPI · ROBOTICS ENGINEERING

The Lab

Coursework, treated like product work. Every piece below ran on real hardware or real math.

RBE 1001AUG – OCT 2025

Autonomous fruit-harvesting robot

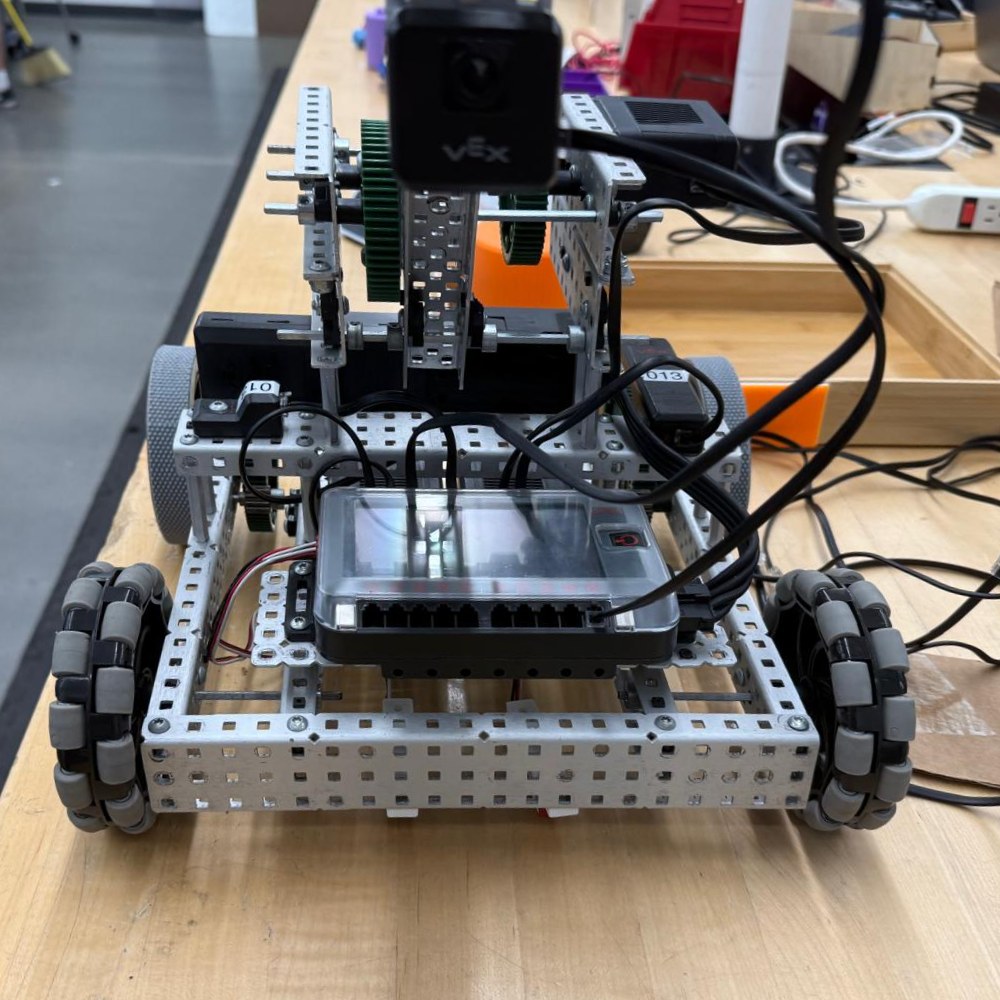
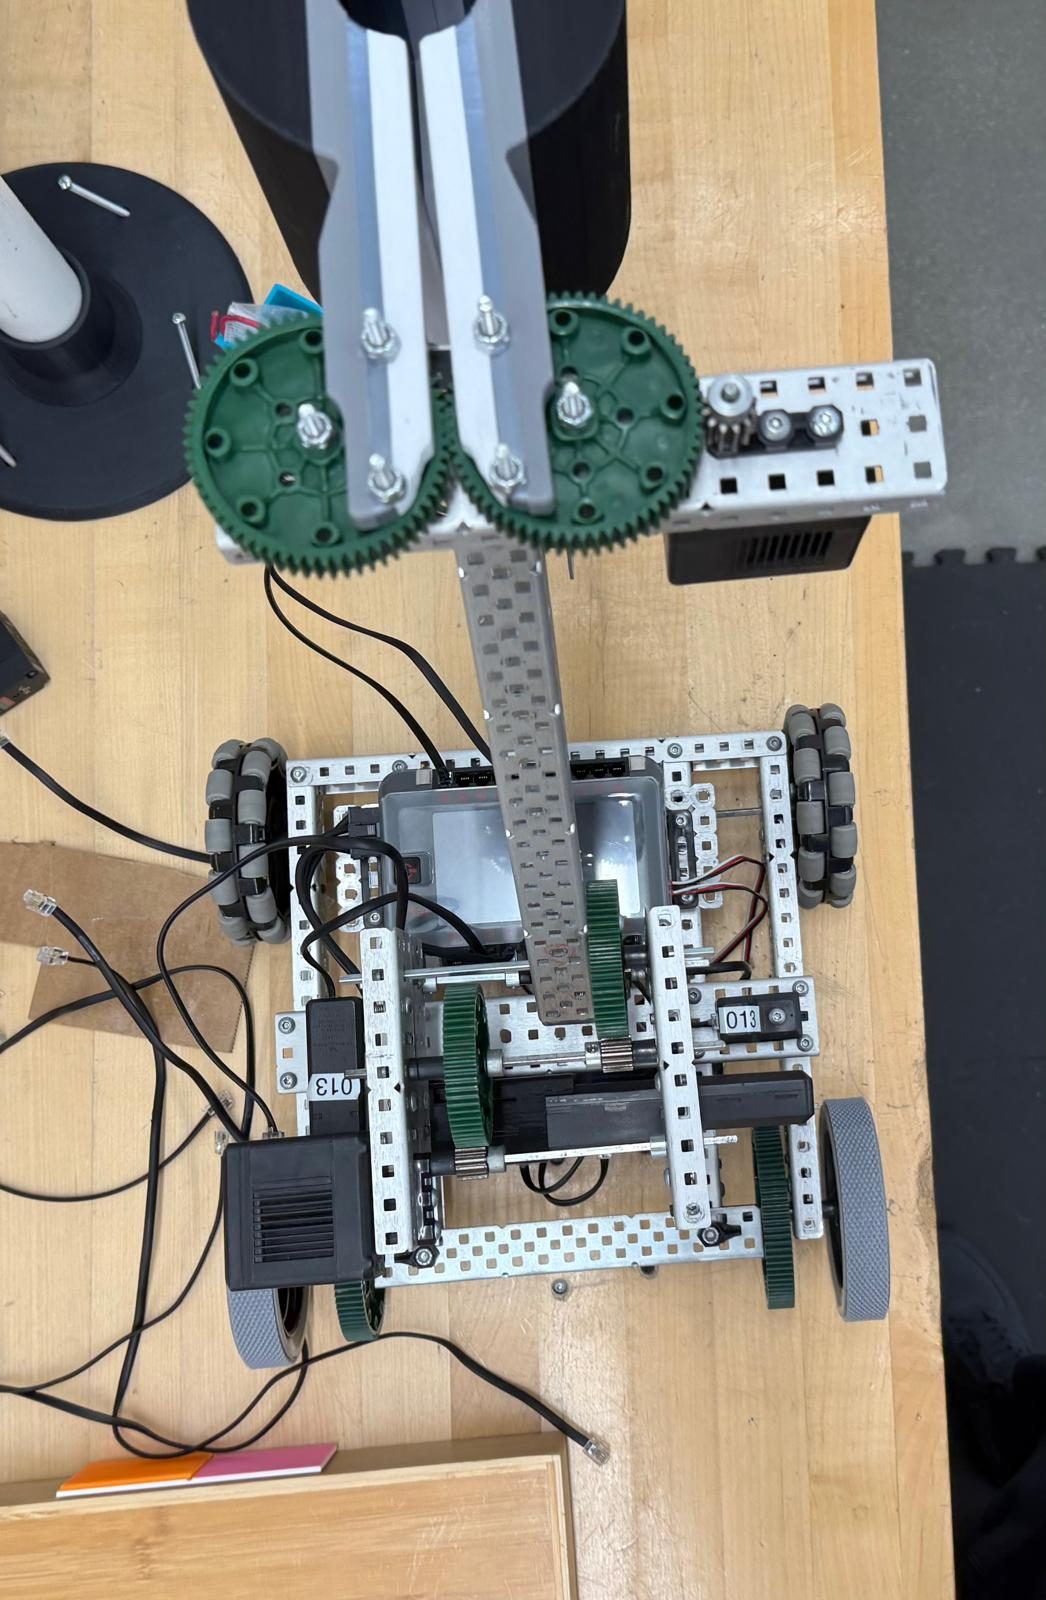
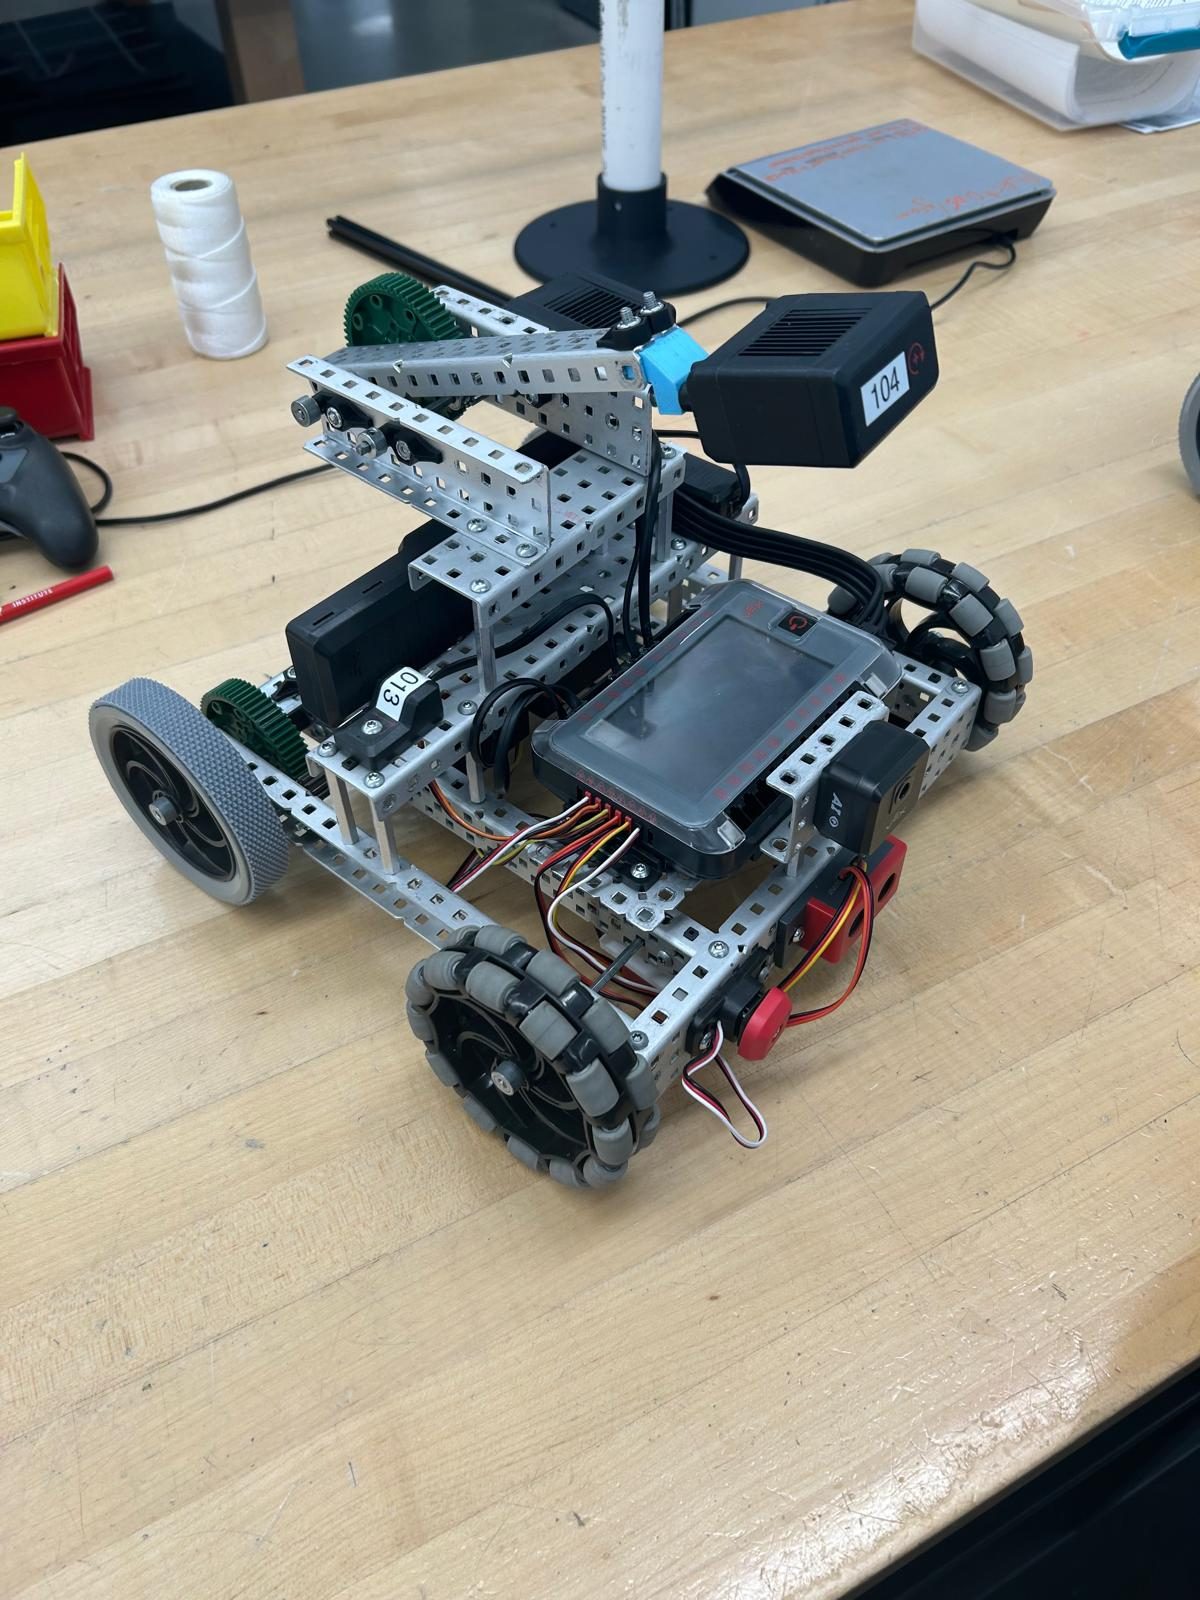
A VEX V5 robot that navigates a set course, finds fruit with a camera, harvests it and delivers it to a basket — fully autonomous, built from modular subsystems.

  1. 1Vision sensor — finds the fruit
  2. 2Geared lift + claw — the harvest
  3. 3V5 Brain — runs the autonomous routine
  4. 4Omni wheels up front — tight turns on course
Front view of the VEX V5 fruit-harvesting robot with its camera mounted on top 1 2 3 4
On the bench at WPI · FIG. 03
AUTONOMOUS · UNCUT
The full run, no hands · 48 s · FIG. 03b
Top-down view of the VEX robot showing the gear-driven arm Three-quarter view of the VEX robot on a lab bench
PERSONAL · PYTHON2026 · ONGOING

2-joint robot arm simulator

Forward kinematics derived by hand, then inverse kinematics, a time-stepped simulation loop and a custom wireframe renderer. No robotics libraries. This panel is that math running live — drag the target, or use the arrow keys.

Where it’s headed: an arm clipped to the side of my desk that picks up stationery and drops my phone on its charger.

# arm/kinematics.py
def forward_kinematics(theta1, theta2):
theta1_rad = math.radians(theta1)
theta2_rad = math.radians(theta2)
elbow_x = L1 * math.cos(theta1_rad)
elbow_y = L1 * math.sin(theta1_rad)
hand_x = elbow_x + L2 * math.cos(theta1_rad + theta2_rad)
hand_y = elbow_y + L2 * math.sin(theta1_rad + theta2_rad)
return (elbow_x, elbow_y), (hand_x, hand_y)
L1 = 180 mm · L2 = 180 mm
θ1 — θ2 — HAND — —
RBE 100XAUG – OCT 2024

Autonomous navigation

Modular Python classes: a DriveTrain for motor and IMU control, a GridWorld for mapping and pathfinding, and a PathDriver for node-to-node driving.

Paint walls. Drag S and G. Watch it search the map, commit to a path, and drive it one node at a time.

ALGO A* EXPANDED — PATH —
RBE 2020JAN – MAR 2026

Embedded systems

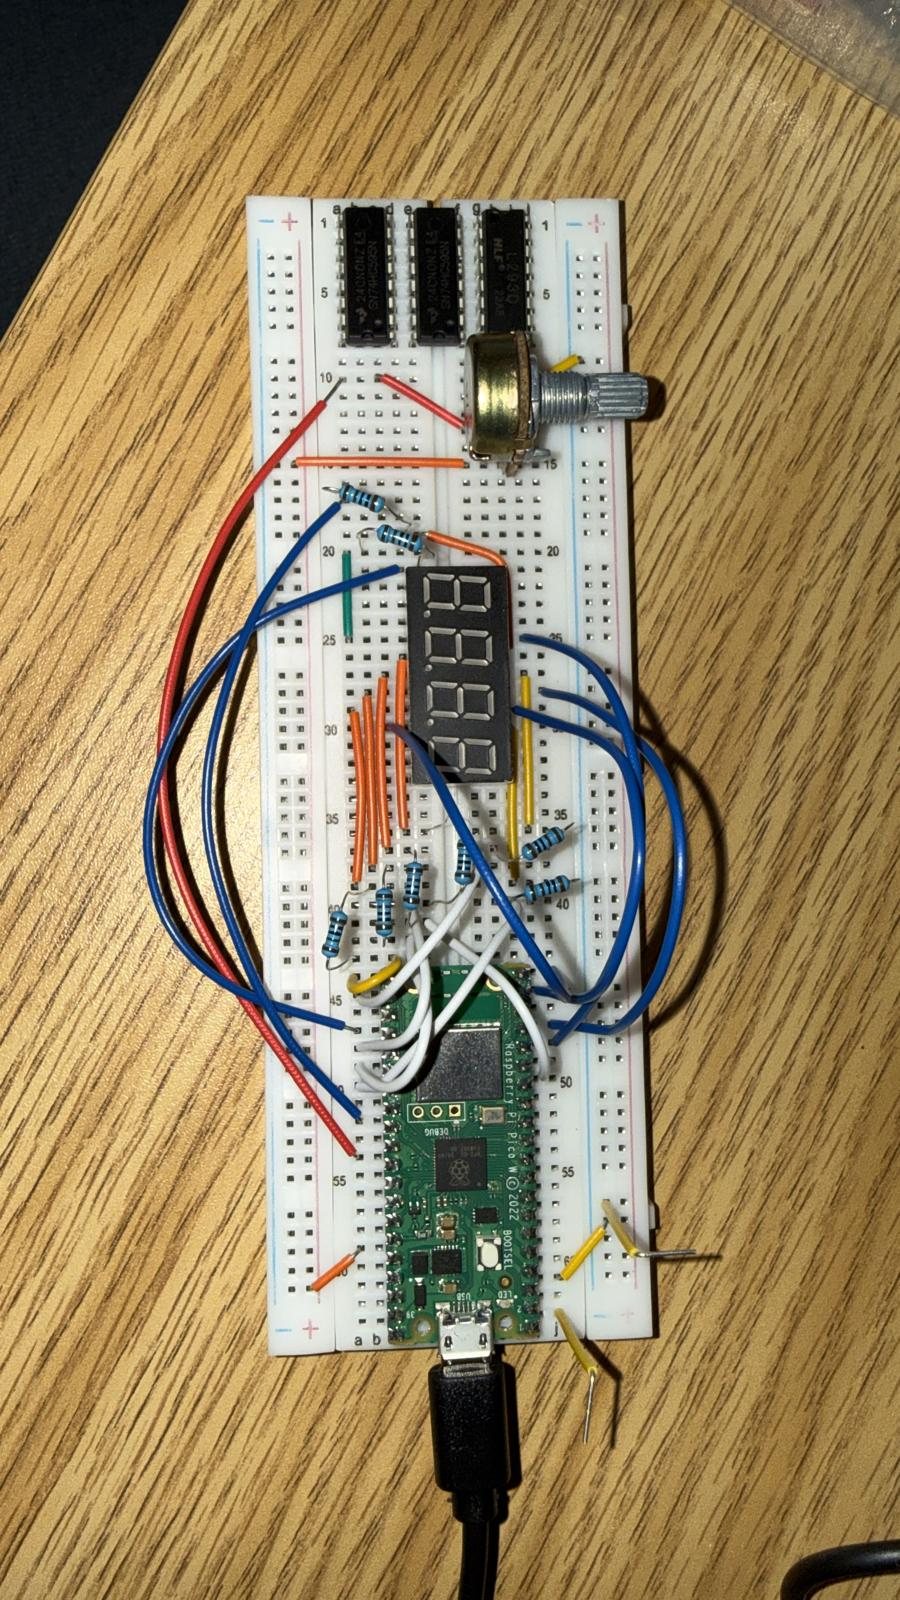
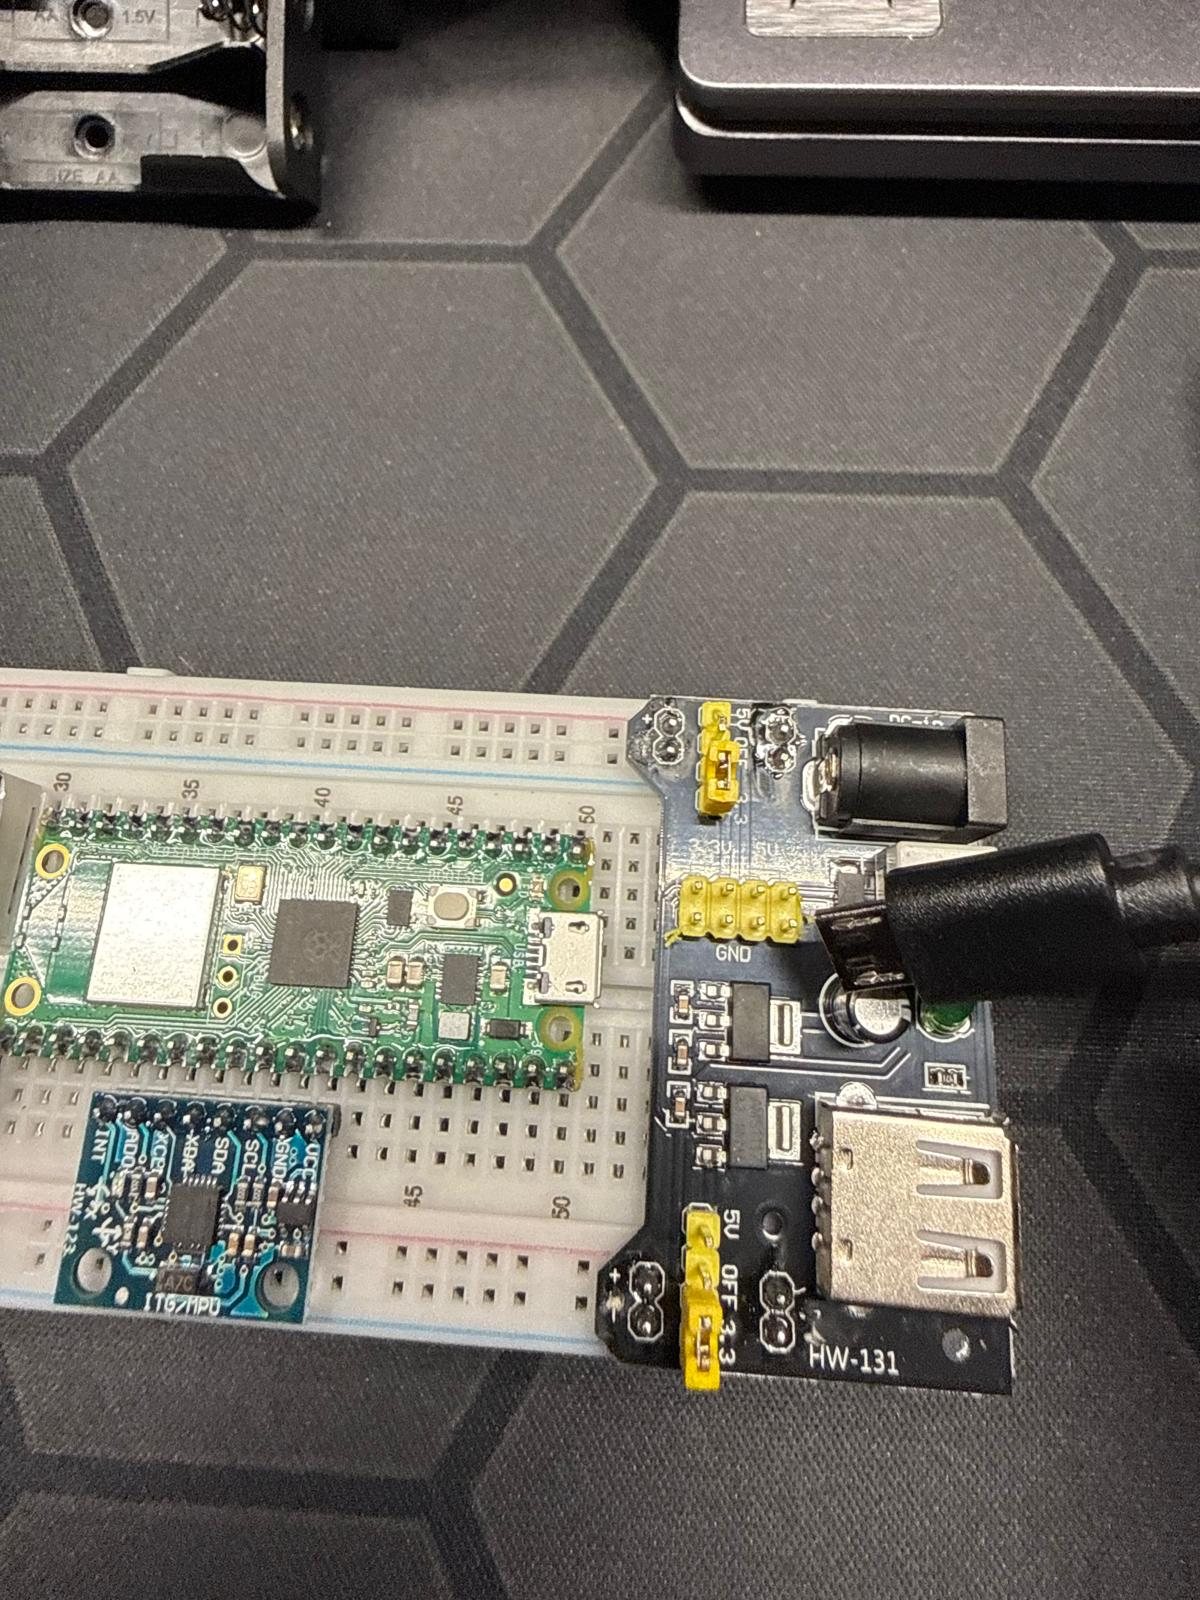
Real-time microcontroller programs in embedded C/C++: sensors, actuators, PWM, ADC, I²C and interrupt-driven control. Low-level hardware behaviour debugged at the waveform; circuits drawn in KiCad.

F 1.0 kHz VAVG 3.10 V
Breadboard with a Raspberry Pi Pico W, a 4-digit 7-segment display, an L293D chip, resistors and a potentiometer L293D POT → ADC 4 × 7-SEG PICO W
Raspberry Pi Pico W on a breadboard next to an MPU-6050 motion sensor and an HW-131 power module PICO W MPU-6050 · I²C 3.3 / 5 V RAILS
RBE 2020 bench builds: wired by hand, debugged at the pin · FIG. 04

Slide the duty cycle: the square wave is what the pin does; the cyan trace is what the motor feels.

SOLIDWORKS · ONSHAPE · CADQUERY

CAD that comes apart

Three tools, one habit: parameters first. Parts, assemblies, drawings and motion studies — the same muscle that turns Rocky’s CadQuery model into a SOLIDWORKS rebuild.

ARMV3_TOPSHELF.STEP · LIVE
DRAG TO ORBIT
RBE 2001 · UNIFIED ROBOTICS IA-TERM 2026 · FINAL PROJECT
ArmV3 · top-shelf arm

A tower arm on the Romi. An MG996R servo drives the lift through a 25-tooth pinion into 50-tooth gears cut into the arm links — a 2:1 reduction. A four-bar linkage keeps the gripper level on the way up; an SG90 closes it. The shelf, cubes and Romi are in the model as reference so every reach is checked in CAD first.

// bill of materials, from the STEP
MG996R servo × 2 · SG90 servo × 1
pinion 25T × 2 → arm gear 50T × 2 = 2 : 1
link 140 × 2 · rod 120 · rod 140 · triangle
fixed jaw + finger
M3 screws, nuts, spacers × 42
58 MODELLED PARTS 5 REFERENCE BODIES HOVER A PART TO NAME IT
ES 1310 · SOLIDWORKS · exploded view · motion study
ES 1310 · SOLIDWORKS · reveal box · assembly animation
REEL 04 — ANTHEON GAME SERIES · 01UNITY 6 · 2.5D
ECHOBLOOM

A world that lost its human voices. Only a pulse lights the dark.

CLICK ANYWHERE TO SEND A PULSE

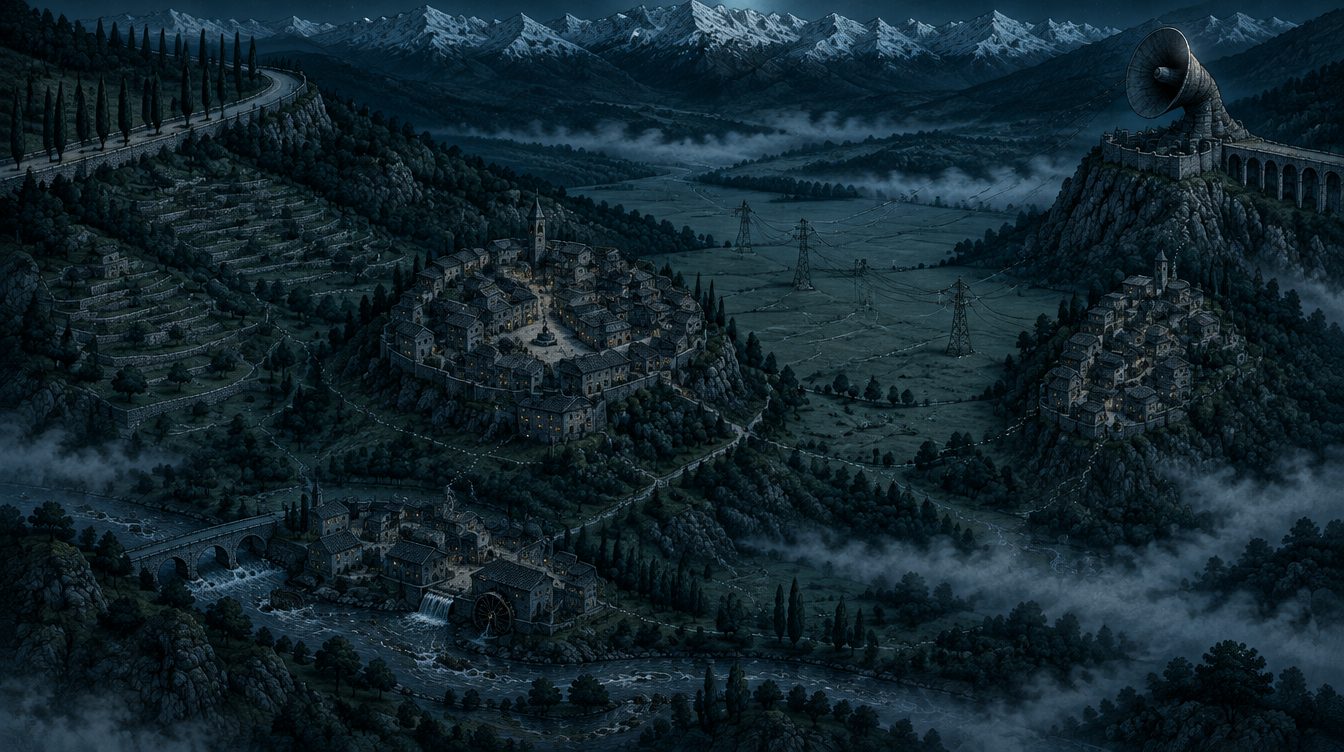
A short atmospheric exploration game: one dense mountain valley, a silent world, and a listener who can still be heard.

  • THE PULSE — reveals the dark and wakes sound fossils.
  • THE CALL — an aimed cone; the world answers it.
  • ONE LIGHT — the voice. Everything else stays black.
  • THE CAMERA — side-on, Unity 6 URP; it never turns.
  • GATES, NOT DATES — target frame → grey-box verbs → the ending.
Concept: the Listener sends a pulse ring across dark grass
The Pulse
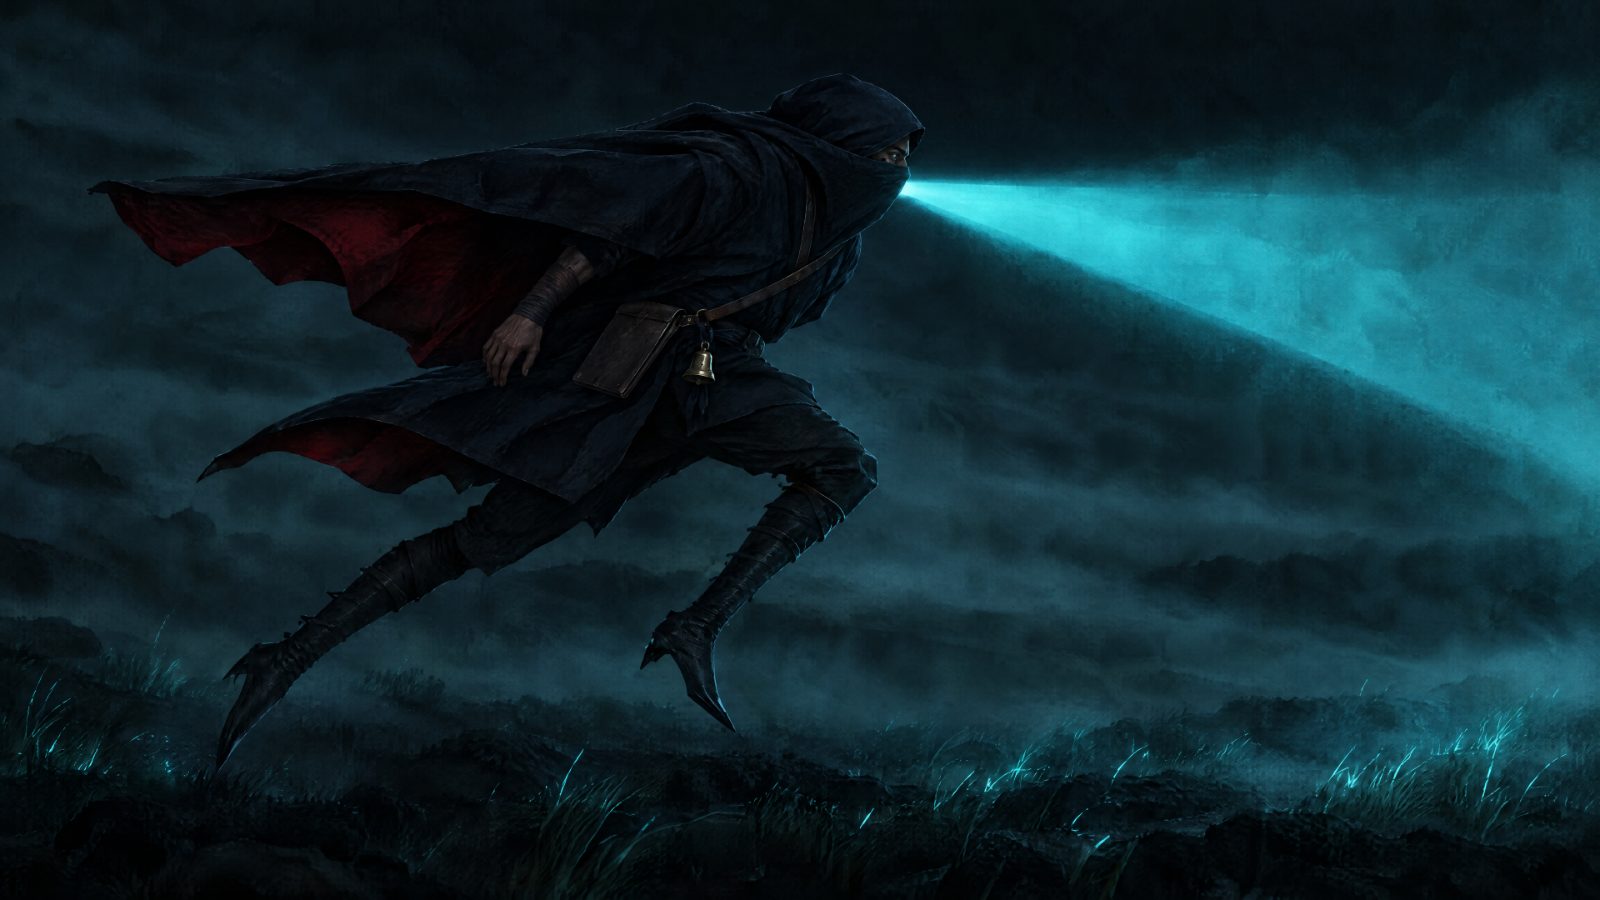
Concept: the Listener leaps, projecting a cone of cyan light
The Call
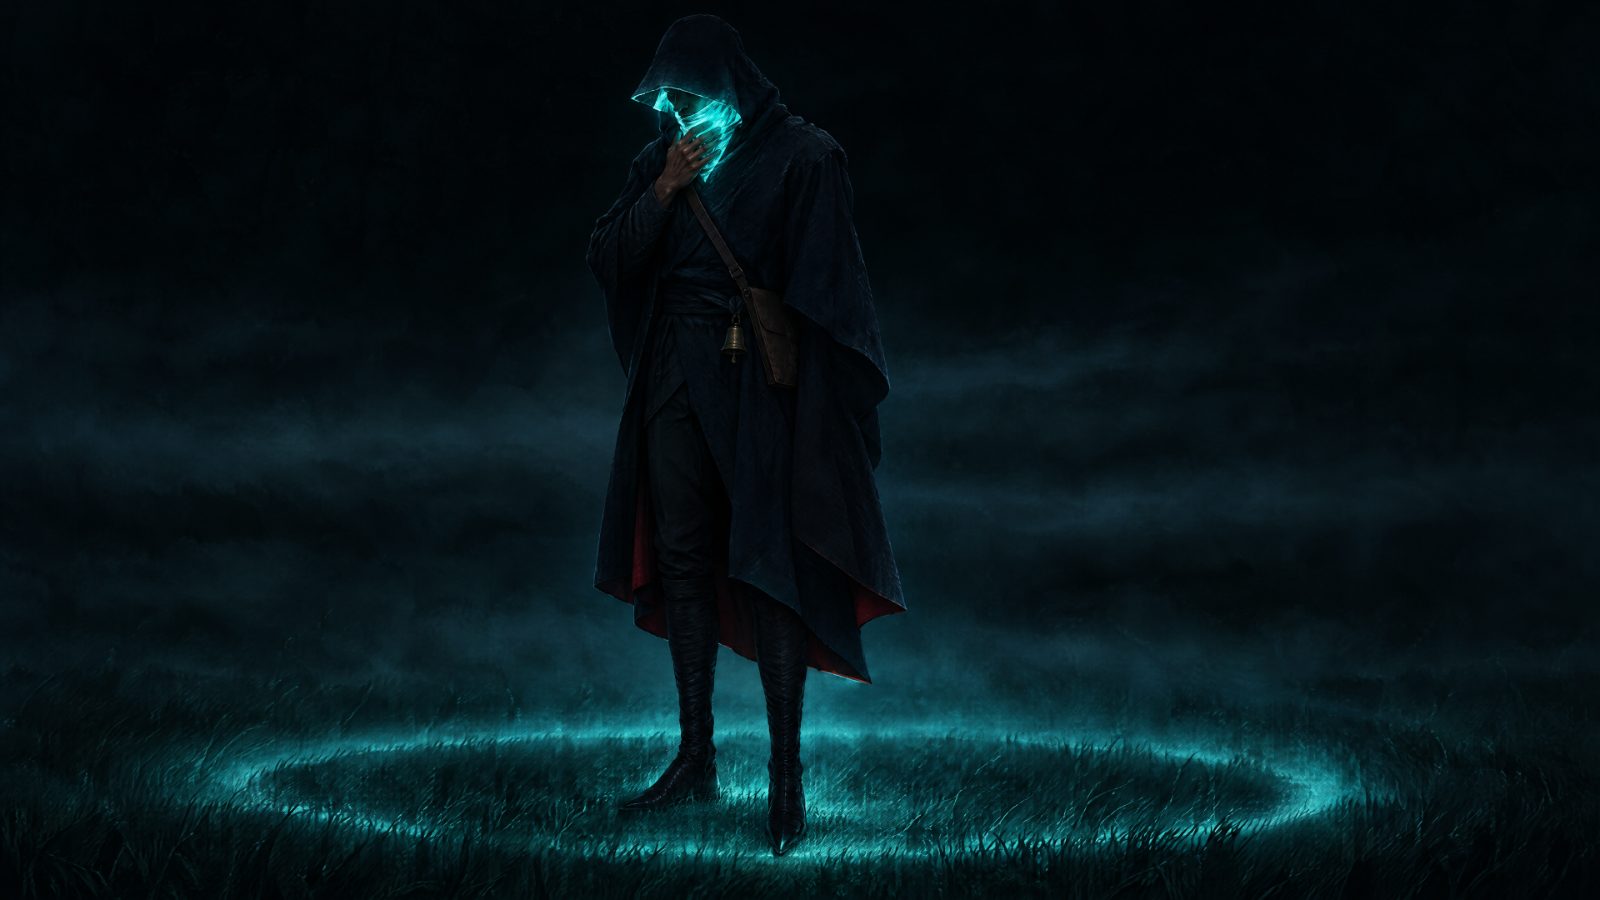
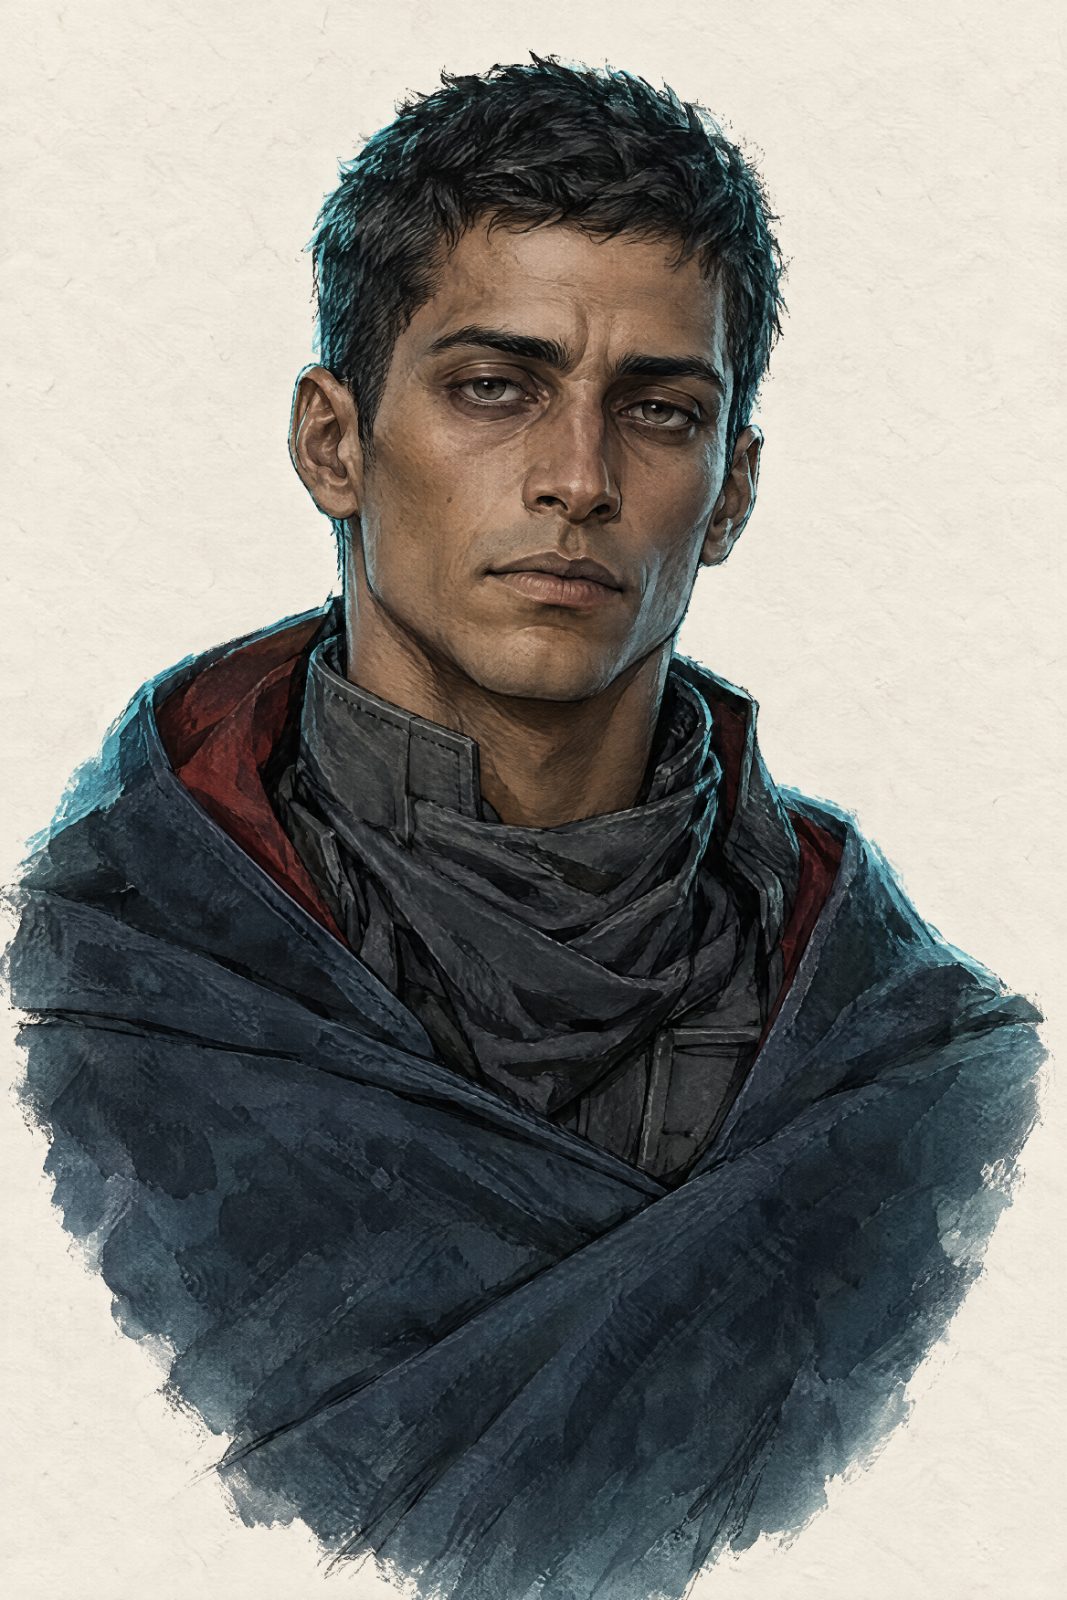
Concept portrait of the Listener in a dark wrapped cloak
The Listener
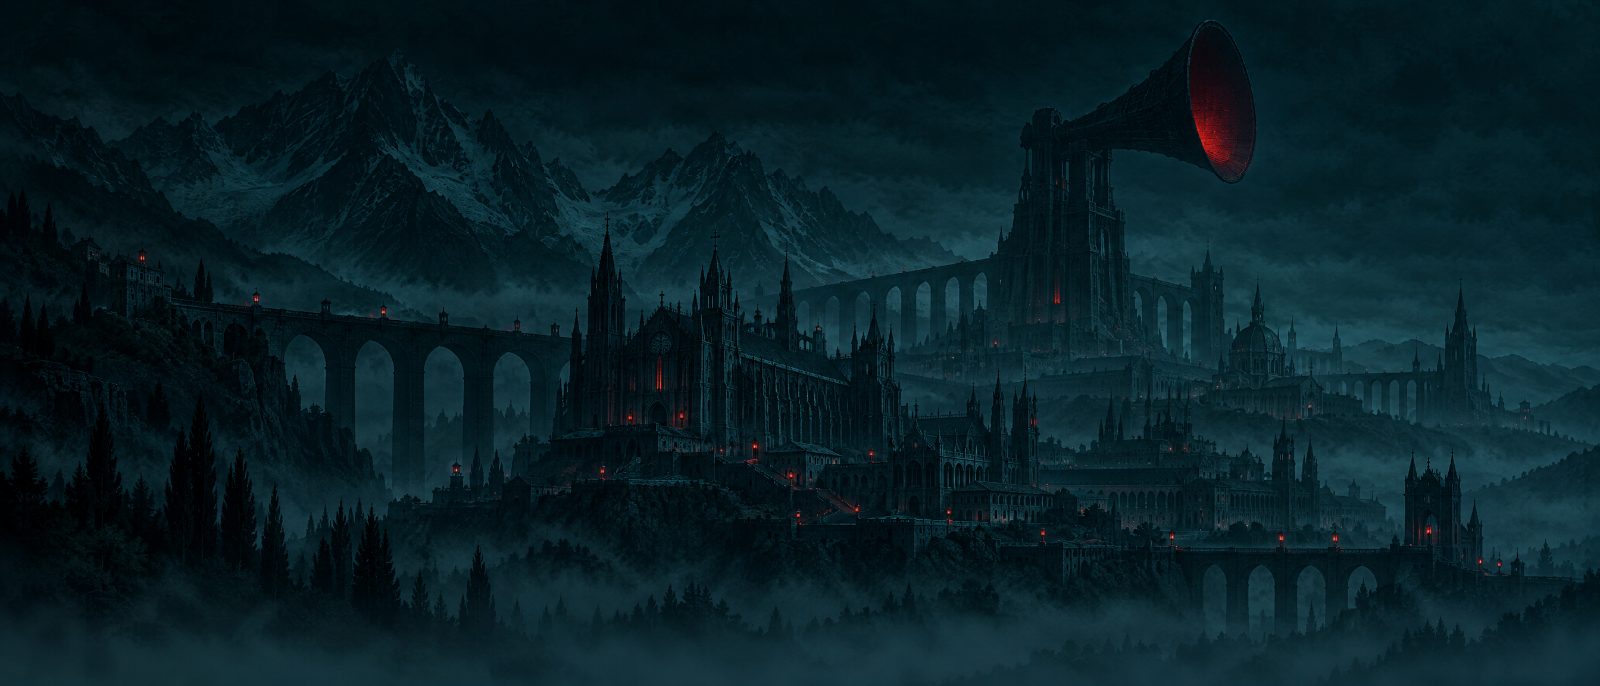
Concept: a dark city under a giant horn on a mountain ridge
The horn over the valley
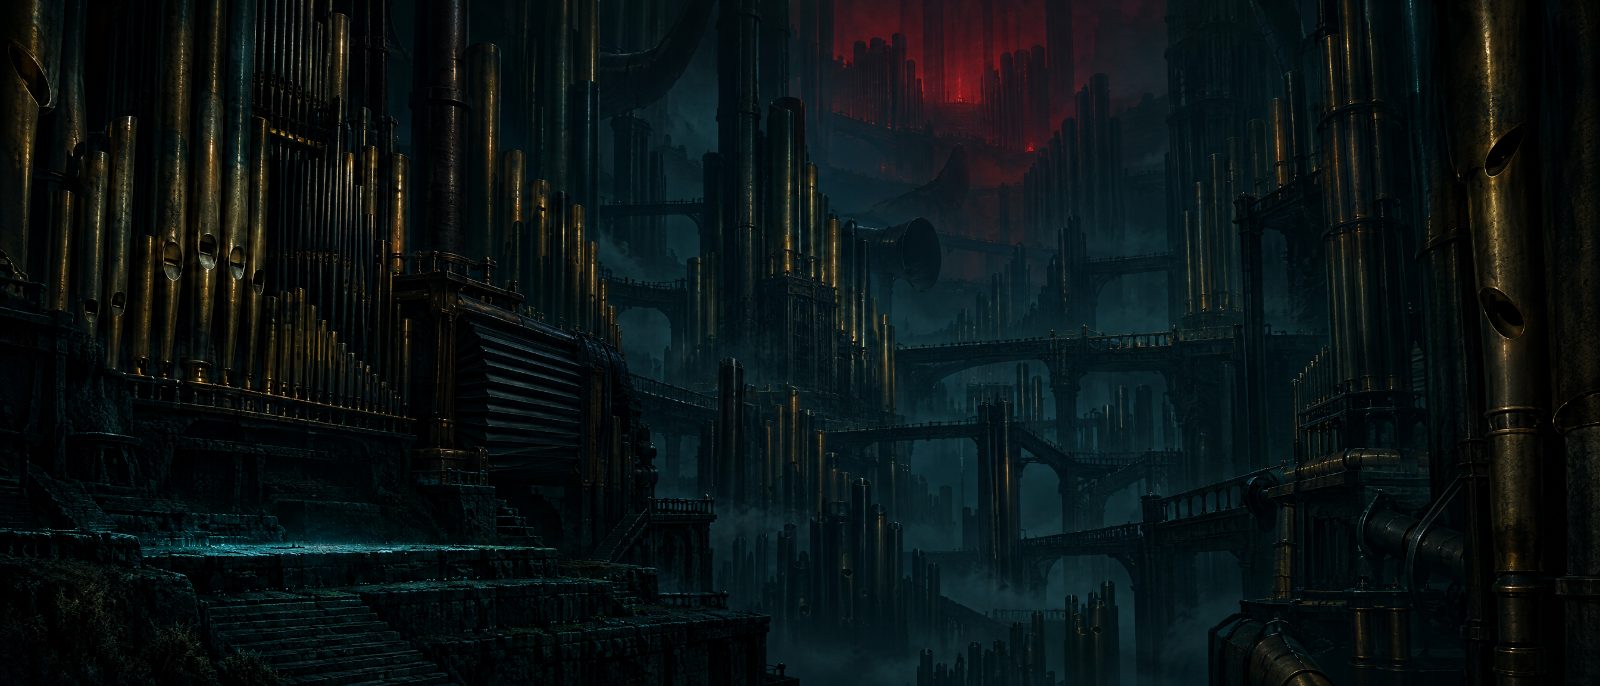
Concept: a canyon city made of brass organ pipes with a red glow
The organ city
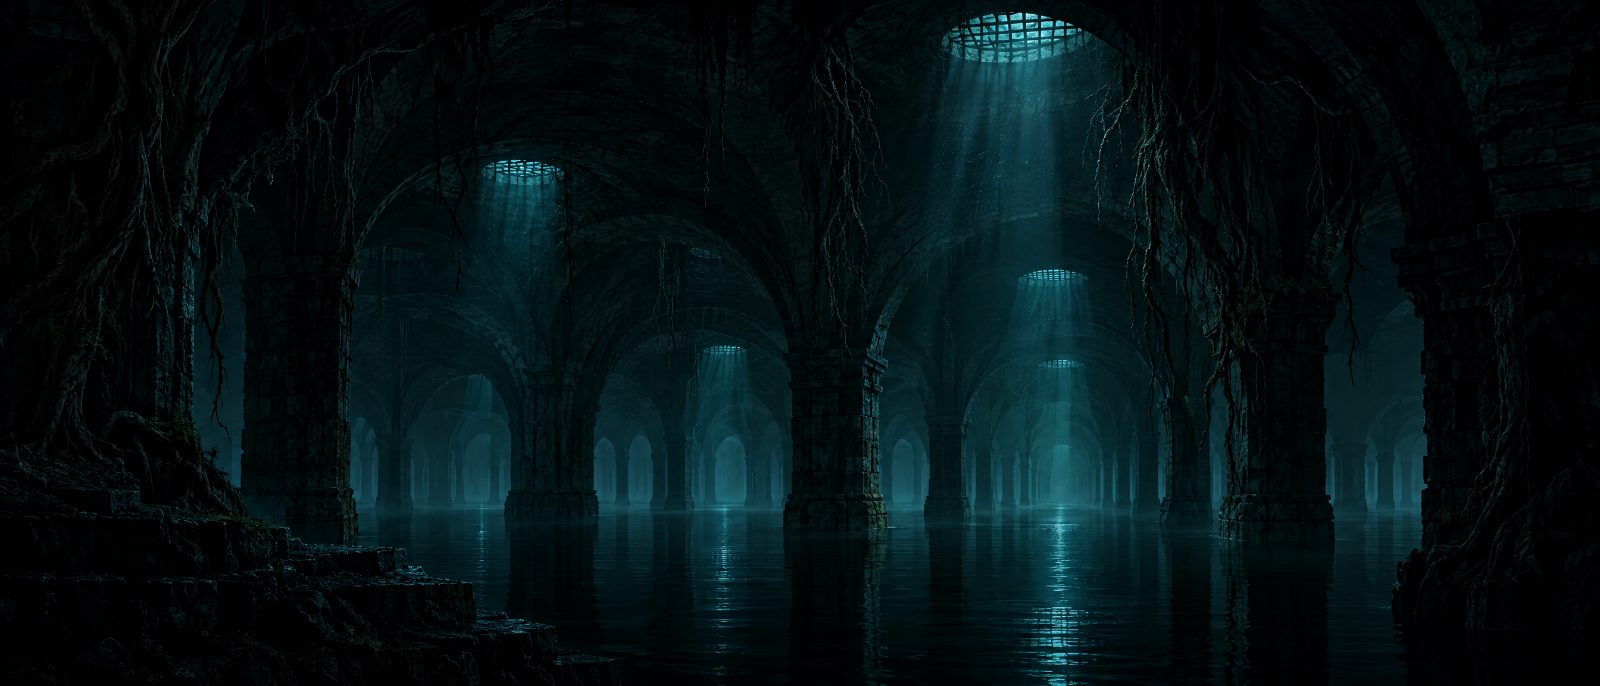
Concept: a flooded underground cistern lit by shafts of cyan light
The cistern
Concept: an overhead map of a mountain valley with villages and a horn tower
The valley, from above
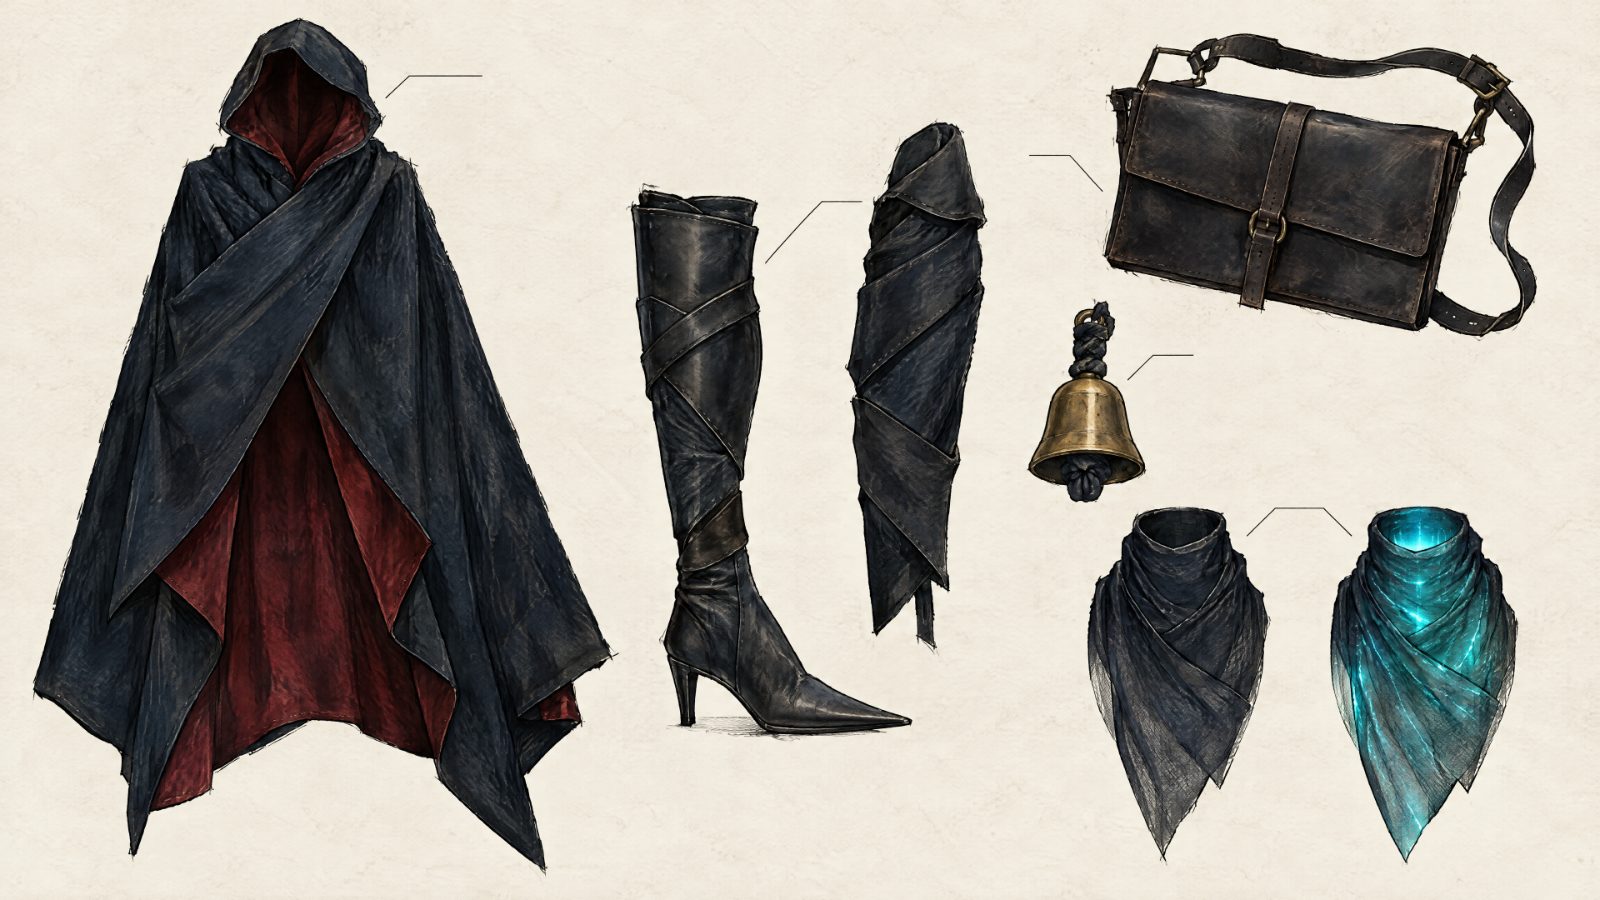
Costume breakdown: cloak, boots, satchel, bell and two scarves
Costume breakdown

AI DISCLOSURE — Concept art made with AI image tools under my art direction, used as modelling reference. Every word of the story is mine.

REEL 05 — INDEPENDENT FILM · LAHORE · AUG 2024 – AUG 2025

Narcolepsia.

Pakistan’s first POV horror film. I produced it and played the lead.

PRODUCER
Syed Mahin Shah
LEAD ACTOR
Syed Mahin Shah
THE JOB
Budget, scheduling, crew coordination and cinematography calls — pre-production through release.
REEL 06 — THE UNGLAMOROUS HALF

Operations

People, process and paperwork that holds when nobody’s watching.

DIRECTOR OF OPERATIONS · FES HIGHER EDUCATION CONSULTANTS · LAHOREJUL 2025 – PRESENT
22
years in business
17
offices · Pakistan, UAE, Malaysia
15,000+
students placed
300+
partner institutions

I rebuilt how the firm runs: a Marketing OS and an Organization OS — 31 documents across four departments, decision rights that keep authority where it belongs, a career ladder from hire to exit, and a logging system of eight register workbooks so every report line points at evidence.

On the partnership side: transnational outreach and MoU pipelines with overseas universities, and the firm’s 14-slide institutional deck rebuilt from flattened source files into a fully editable presentation on a custom design system.

Antheon logo
FOUNDER & SYSTEMS ARCHITECT · 2026 –
Antheon

Builds intelligent machines — and the people who build them. Robotics and AI, Pakistan first. I architect its systems, write the specs, and review every dependency’s licence before it ships.

RESEARCH INTERN · JUN – JUL 2023
LUMS, Lahore

Institutional research under a faculty supervisor: data collection, analysis and written documentation across a two-month on-site placement.

REEL 07 — CONTACT SHEET

The Kit

Grab one. Throw it. Each is honest about its level.

●●○ INTERMEDIATE●○○ BEGINNER
Embedded C/C++ ●●○ PWM · ADC · I²C ●●○ VEX V5 ●●○ SOLIDWORKS ●●○ KiCad ●○○ Onshape ●○○ Isaac Sim ●○○ Isaac Lab ●○○ Gazebo ●○○ PyBullet ●○○ Local LLM inference ●●○ Agentic systems ●●○ Memory + retrieval ●●○ Computer vision ●○○ Model training ●○○ Python ●●○ C/C++ ●●○ MATLAB ●○○ TypeScript ●○○ SQL ●○○ Git ●●○ Linux ●●○ Next.js ●●○ React ●●○ Node.js ●○○ PostgreSQL ●○○ Vercel ●○○ JWT / OAuth ●○○ Producing Acting Operations
ROBOTICS + SIMULATION AI / ML LANGUAGES SOFTWARE + WEB CRAFT
EDUCATION
Worcester Polytechnic Institute

B.S. Robotics Engineering · Minor in Entrepreneurship · expected May 2028

Unified Robotics I & II · Embedded Systems · Social Implications of Robotics · Matrices & Linear Algebra · Fundamentals of Finance

LEADERSHIP & ACTIVITIES
  • WPI, 2024 – Pakistani Student Association · Basketball · Volleyball · SocComm · International Student Council
  • ROOTS IVY College, 2022 – 24 President, Podcast Club · IVY-Verse Executive Council · ICATS Distinction · WWF community service
THE STRIP · 2022 → 2028DRAG OR SCROLL →
2022
ROOTS IVY College. Podcast Club president, IVY-Verse executive council.
2023
Research intern at LUMS. ICATS Distinction.
2024
Moved to Worcester. Robotics Engineering at WPI. First autonomous robot (RBE 100X). Narcolepsia goes into pre-production.
2025
Narcolepsia released. Director of Operations at FES. The fruit-harvesting robot (RBE 1001).
2026
Founded Antheon. ERIS into Phase 3. Embedded systems. The arm simulator. Rocky speaks for the first time.
2028
Graduation, May. To be continued.

A Syed Mahin Shah production

ROBOTICS ENGINEER·SYED MAHIN SHAH FOUNDER, ANTHEON·SYED MAHIN SHAH SYSTEMS ARCHITECT, ERIS·SYED MAHIN SHAH DIRECTOR OF OPERATIONS, FES·SYED MAHIN SHAH PRODUCER·SYED MAHIN SHAH LEAD ACTOR·SYED MAHIN SHAH CAD, PCB & FIRMWARE·SYED MAHIN SHAH GAME DESIGN & STORY·SYED MAHIN SHAH DESK ROBOT·ROCKY COMIC RELIEF·ROCKY SUPERVISING AI·ERIS FILMED ON LOCATION·WORCESTER · LAHORE

No robots were harmed in the making of this site. Several were exploded.

POST-CREDITS SCENE

Let’s make
the next one.

Internships, research, collaborations, press — or you just want to argue about robot names. I read everything.

SEND A MESSAGEENCRYPTED IN TRANSIT
Message received.

Rocky is driving it across the desk. I’ll reply from syedmahinshah@gmail.com.

{{ formError }}

Protected by a honeypot, a time check and rate limiting. Never sold, never shared, deleted after 12 months.

REEL INDEX
ESC TO CLOSE · THERE IS A SECRET IF YOU TYPE HIS NAME
SECRET REEL · DESK RUN
{{ toast }}